Image courtesy of the OpenSimulator Community Conference
The 2016 OpenSimulator Community Conference is in progress over the weekend of December 10th / 11th. An annual event, the conference focuses on the developer and user community creating the OpenSimulator software. It is organised as a joint production by Core Developers of OpenSimuator and AvaCon, and this year is sponsored by University of California, Irvine, Institute for Virtual Environments and Computer Games, Rockcliffe University Consortium, and Virtual Outworlding together with a host crowdfunders.
The conference this year once again features business presentations, talks, panel discussions, workshops, social events and hypergrid activities, covering a wide range of subject areas, including education, social VR, using virtual worlds and environments for historical recreations – and much more besides.
You can find the full schedule of events on the OpenSimulator Community Conference website, together with instructions on how to log-in and join and of the sessions. The latter are also being streamed for those unable to attend via avatar.
Image courtesy of the OpenSimulator Community Conference
The NASA Eagleworks EmDrive prototype. Credit: NASA Eagleworks / NASA Spaceflight Forum
The radio frequency (RF) resonant cavity thruster, or EmDrive (pronounced “M-drive”) as it is more popularly known, has been a source of much controversy since the idea first came into the public eye around 16 years ago, and the debate has been heating up again over the last few months.
First proposed by British engineer Roger Shawyer in 1999, the EmDrive is supposed to be the world’s first working reactionless drive, a means of generating thrust without the use of any propellant. Over the years, it has undergone investigation and testing by a number of organisations and agencies before being quietly pushed aside, while some critics have been publicly scathing of the whole idea, labelling it the “impossible drive” as it violates the fundamental law of conservation of momentum (summed up in Newton’s third law, “for every action, there is an equal and opposite reaction”). Even so, research and testing has continued.
The EmDrive supposedly generates thrust by reflecting microwaves between opposite walls of a cone-shaped cavity. In principle, no microwaves or anything else leaves the device, and so it is considered reactionless – although Shawyer states that it isn’t, because the propulsive force is created by a “reaction between the end plates of the waveguide and the Electromagnetic wave propagated within it.”
The attraction of the drive is that were it to work, it could provide an almost endless supply of thrust for satellites and other spacecraft, opening the door to flights to Mars in just 70 days as opposed to the 180-234 days currently required using conventional means. The problem is no-one has actually got the idea to work. Researchers at the at the Northwestern Polytechnical University (NWPU) in Xi’an, China, thought they had in 2012, but further testing in 2014 revealed the thrust apparently created by their EmDrive test rig was actually due to a faulty power connector causing false readings.
Now, however, it seems that a test rig operated by NASA’s Eagleworks Laboratory might actually have demonstrated that in principle an EmDrive could work. News on the testing has actually been leaking out of the laboratory for the past 2-3 months – and has rightfully been met with a healthy dose of scepticism. However, a paper from the team carrying out the research was submitted for peer-review through the Journal of Propulsion and Power, a publication maintained by the American Institute of Aeronautics and Astronautics (AIAA) – and is said to have passed muster.
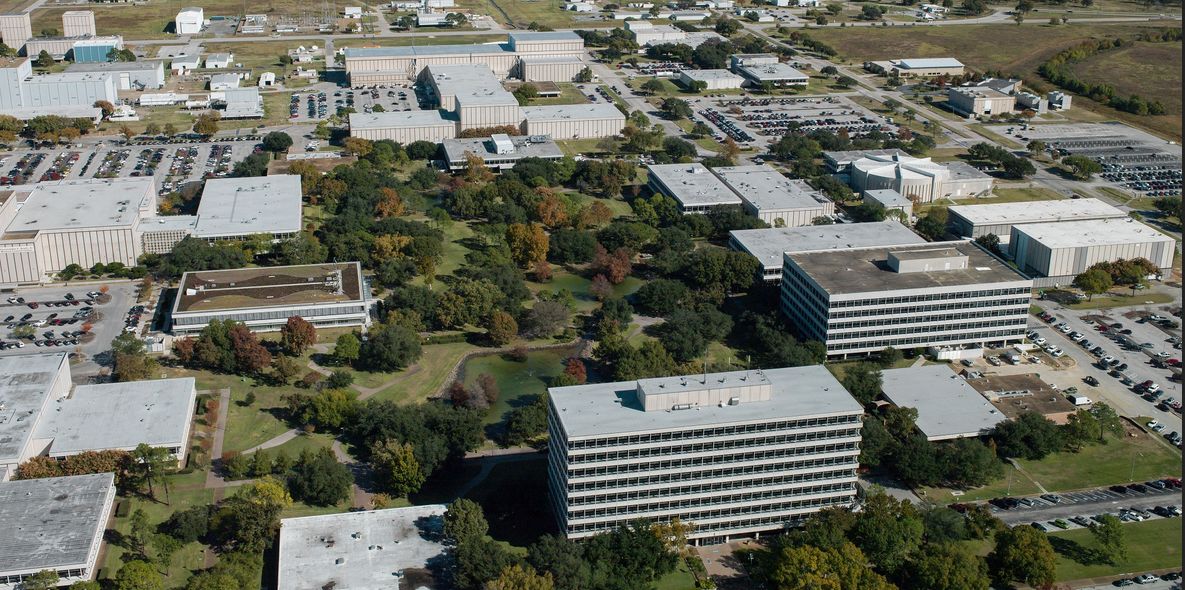
NASA’s Johnson Space Centre, Texas, the home of the Eagleworks Laboratory. Credit: NASA / James Blair
So, does this mean the EmDrive works? Well – no. The peer-review process means that no discernible flaws have been found in the methodology and testing carried out by the Eagleworks team, meriting the idea worthy of further investigation and research. It doesn’t mean fault or error may not yet be found going forward.
One major means of testing the theory of the EmDrive would be to build a working unit and place it in space and see if it works. This is precisely what US engineer Guido Fetta hopes to do. He is planning to place a small version of his Q-Drive (derived from the EmDrive) in orbit for 6 months aboard a CubeSat (between 10×20×30 cm and 12×24×36 cm in size), and then try over six months to manoeuvre the CubeSat using the drive. He’s not alone; China similarly plans an on-orbit test of an EmDrive prototype, although no dates have been specified for them mission.
Did Spirit Find Signature of Past Martian Life?
NASA’s MER rover, Spirit (MER-A) and Opportunity (MER-B) arrived on Mars in January 2004, and Opportunity continues to explore the planet today. Credit: NASA / JPL
In January 2004, NASA landed two solar-powered rovers, Spirit and Opportunity on Mars. There primary mission was scheduled to last just 90 days – but Opportunity is still operating today, almost 13 years after it arrived on Mars. Sadly, Spirit was not so lucky; in May 2009, it became stuck in a “sand trap” and unable to free itself, eventually losing power as its solar panels could not be oriented towards the winter Sun on Mars, and falling silent in May 2010.
Nevertheless, Spirit gathered a huge amount of data and images, some of which is being re-examined by scientists Steven Ruff and Jack Farmer from Arizona State University as a result of their field expeditions to Chile – and they believe the rover may have come across evidence for past Martian life.
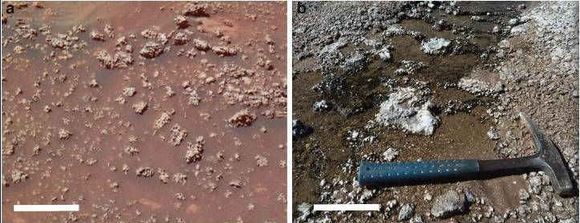
While examining images of a plateau of layered rocks dubbed “Home Plate”, examined by Spirit in 2006, Ruff and Farmer noticed the ground was covered in multiple nodular masses of opaline silica with digitate structures strikingly similar to structures they have encountered within active hot spring/geyser discharge channels at a site in northern Chile called El Tatio.
This is a region which, due a rare combination of high elevation, low precipitation rate, coupled with a high ultraviolet irradiance, is regarded as a potential analogue for past conditions on Mars. What’s more, as a volcanic are, it shares much in common with “Home Plate”, which is believed to be an explosive volcanic deposit created when hot basalt rock came into contact with liquid water. Part of the formation may actually be an extinct Martian fumarole.
An image of “Home Plate” showing a mass of opaline silica nodules, captured by NASA’s Spirit rover in 2006, and a photograph showing similar formations at El Tatio, Chile Credit: ASU/Ruff & Farmer
The opaline silica Ruff and Farmer found at El Tatio have been shown to be largely of biotic origin; that is, created by microbes. Could this be the same for those Spirit saw at “Home Plate” in 2006? Ruff and Farmer believe it might.
“Although fully abiotic (physical rather than biological) processes are not ruled out for the Martian silica structures, they satisfy an a priori definition of potential biosignatures,” the researchers state in a paper on their work. A biosignature is defined by NASA as “an object, substance and/or pattern that might have a biological origin and thus compels investigators to gather more data before reaching a conclusion as to the presence or absence of life.”
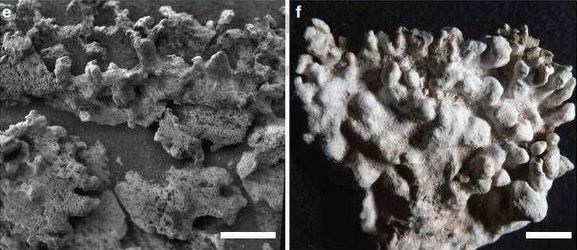
A closer view of the structures as images by Spirit in 2006, and a an image of the opaline silica at El Tatio taken at the same distance and resolution. Credit: ASU/Ruff & Farmer
Ruff and Farmer note that while they cannot prove nor disprove a biological origin for the structures imaged by Spirit at “Home Plate”, they should be regarded as a potential biosignature by NASA’s own definition of the term. They go on to state that the only way to be sure would be for a robust examination to be made of the “Home Plate” location, perhaps by NASA’s upcoming Mars 2020, were it to be sent to that region, or through the examination of another region of Mars which is identified as being geographically and geologically similar.
Virgin SpaceShipTwo Flies
Virgin Galactic’s SpaceShipTwo vehicle, VSS Unity completed its first free flight test on Saturday, December 3rd, after a month’s delay due to a combination of high winds and an unspecified technical issue, which combined to leave the vehicle able to make just a single captive / carry flight with its carry / launch aircraft, WhiteKightTwo.
VSS Unity seen from a chase plane as it glides towards touch-down on Saturday, December 3rd, 2016. Credit: Virgin Galactic
The unpowered flight, took place over the Mojave Air and Space Port in California and was the first in a series of around 10 – the precise number will depend on how well the targets for each flight are met – such tests the vehicle will make before Virgin Galactic move to powered flight tests using their new rocket motor for the vehicle, which has so far only been tested on the ground.
“It’s a happy day to be here,” Virgin Galactic’s founder, Sir Richard Branson said just before WhiteKnightTwo lifted SpaceShipTwo aloft. “We’ve got an exciting year ahead, and this is just the start of it.”
VSS Unity comes to rest on the runway after a successful first flight test. Credit: Virgin Galactic
As TGO Flexes Its Muscles, More Ice Found on Mars
ESA’s Trace Gas Orbiter (TGO), which arrived in orbit around Mars in October, has yet to reach its primary science orbit but it is already flexing its muscles.
On November 22nd, as TGO swept over Mars on one of its current 4.2 day elliptical orbits, a test was carried out on its ability to relay data from the Martian surface to Earth, acting as a go-between for both the Curiosity and Opportunity rovers. As well as carrying a suite of science instruments and camera systems, TGO also carries a communications relay package from NASA called Electra, which allows the spacecraft to successful receive and store communications from NASA’s surface vehicles and then relay them to Earth.
Currently, TGO’s orbit carries it from just 300km (200 mi) above the surface of Mars all the way out to 98,000 km (60,000 mi), limiting its effectiveness as a communications relay. However, this will be lowered and circularised in the coming months to just 400 km (250 mi) above the planet, at which point TGO will be perfectly positioned to carry out its primary science mission and act as a relay for current and future surface missions, including Europe’s own ExoMars rover.
The relay test came at a time when ESA were working on calibrating TGO’s instruments during the close flights over Mars in each of it current orbits around the planet. These calibration tests included initial use of the orbiter’s “eyes”, the Colour and Stereo Surface Imaging System (CaSSIS), which yielded, in the mission team’s words, “spectacular” results.
CaSSIS is an impressive system, capable of capturing still images and video across a number of colour wavelengths, and in 3D if required. All of CaSSIS’s capabilities were exercised during the test as the orbiter passed over Hebes Chasma, an eight km (5 mi) deep trough just to the north of the mighty Valles Marineris. The images collected during the pass have a resolution of 2.8 metres per pixel. To put that in perspective, it’s the equivalent of flying over New York city at 15,000 km/h (9,375 mph) and simultaneously getting sharp pictures of cars in Philadelphia.
The stereo capabilities of CaSSIS will allow scientists to build topographical 3D images of the surface on Mars, such as this test model, built from images of the Noctis Labyrinthus at the north-eastern end of the Vallis Mariners. Credit: ESA / Roscosmos / CaSSIS / UniBE
Once TGO reaches its operational orbit towards the end of 2017, CaSSIS will be capable of acquiring 12-20 high-resolution stereo and colour images of selected targets per day.
Meanwhile, NASA’s Mars Reconnaissance Orbiter (TGO) has located another gigantic water ice deposit lying just under the Martian surface. The ice, lying beneath the planet’s Utopia Planitia, was located using MRO’s ground-penetrating Shallow Radar (SHARAD) instrument.
Utopia Planitia: home of a massive water ice deposit the size of New Mexico, and sitting just below the surface of Mars – click for full size. Credit: NASA
Estimated to be bigger than the US state of New Mexico and containing more water than Lake Superior, it is the second massive ice deposit SHARAD has found in just over a year. The first exists as a deposition averaging 40 metres (604 ft) think, extending almost all the way from the planet’s mid latitudes up to north polar region and covers an area the size of Texas and California combined.
The ice under Utopia Planitia – the landing site for NASA’s Viking 2 mission of the 1970s – is between 80 to 170 metres (260 feet to 560 ft) in thickness, comprises around 85% water ice (the rest being dirt and other deposits), and – most crucially – lies between 1 and 10 metres (3 and 30 ft) beneath the surface, potentially making it an accessible resource for future human missions to Mars.
NASA Considering Foreshortening Orion Crewed Flight
NASA is considering a shorter mission for the first crewed flight of its Orion Multi-Purpose Crewed Vehicle.
Originally, the flight was to have comprised a “slow cruise” out to the Moon of between 3 and 6 days, followed by three days in lunar orbit before making a similar 3-6 day “slow cruise” back to Earth. However, under the new plans being considered, Orion and its crew would be placed in a high Earth orbit (HEO) with an apogee of 35,000km (21,875 mi), where it would remain for a day, before separating from the Exploration Upper Stage (EUS) of its Space Launch System rocket and suing its Service Module motor to enter a trans-lunar injection orbit, for a single free-return flight around the Moon without ever going into orbit there.
Orion’s first mission may now only comprise a flight around the Moon, rather than orbiting it. Credit: Cosmic Pearl
“We’ve effectively designed this mission to be commensurate with the amount of risk we’re taking with crew on the vehicle for the first time,” Bill Gerstenmaier, NASA associate administrator for human exploration and operations said when announcing the new plan. “We’ve tailored the mission to be appropriate with the risk we’re willing to take.”
Two particular risks worried mission planners: a failure with the Orion’s life support system in what would be its first space-based test with a crew aboard, or a failure with the Service Module’s engine which might leave them stranded in Lunar orbit. The redesigned mission means the life support system can be tested whilst in HEO, and the service module motor only needs to be fired once, when boosting Orion towards the Moon.
The revised Exploration Mission 2 flight plan (click to enlarge). Credit: NASA
The change in approach does not affect the Exploration Mission 1 flight, scheduled for 2018. That mission is expected to last around 25 days, with an uncrewed Orion vehicle placed in lunar orbit for several days before it returns to Earth. However, it does open the door to a more gradual approach to extending Orion’s capabilities, with NASA now planning one Exploration Mission a year being flown between 2023 and 2030.
Most of these flights will be cislunar operations, with EM-6 (2026) earmarked as the asteroid rendezvous mission originally scheduled to take place in 2023 as EM-3, but which has been pushed back as a result of delays in the Asteroid Redirect Mission (ARM), its necessary precursor. EM-10 would mark the likely transition from cislunar missions to BEO (“Beyond Earth Orbit”) missions directed towards Mars, utilising Orion and expanded capabilities such as habitat modules and possible nuclear-powered propulsion units.
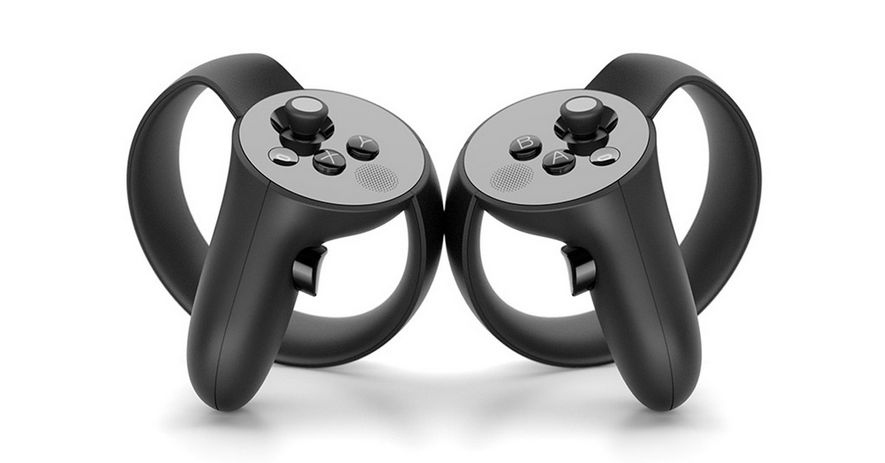
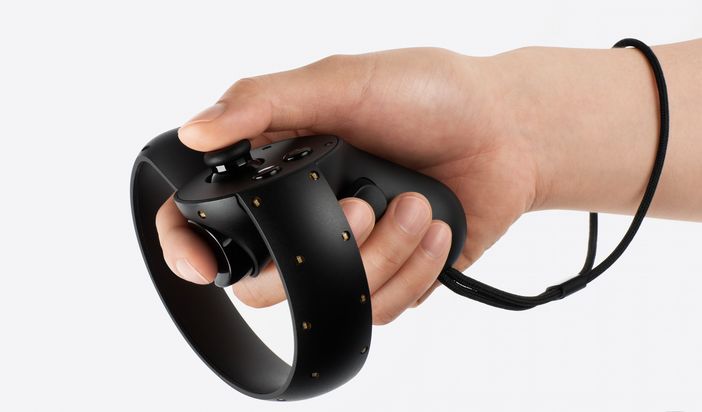
Oculus Touch: shipping December 6th, price: US $199.00
It’s been a while since I’ve covered anything in the VR and AR markets, so here’s a very quick catch-up on the main products I have been following on-and-off in these pages, and about which I’d been meaning to write about during October / November.
Oculus Rift: Touch and AWS
In October 2016, Oculus Rift opened the doors to pre-orders of the Touch, their hand controller system, due to start shipping on December 6th, 2016. The Touch price point is US $199.00 (approx. £189 / €187 / AU $265), which includes of Toybox, the multiplayer sandbox application designed specifically to show-off the controllers, and five Touch-ready game tiles.
Alongside of the Touch, Oculus announced additional Rift sensors would also be shipping on December 6th, 2016, at a price of US $79 (approx. £62.55 / €74.18 / AU $106.47), offering similar room-sized scanning capability as the HTC Vive. A new earbud system, designed to replace the earphones on the headset for a more immersive sound experience, was also made available for pre-order (again shipping on December 6th, at a cost of $49 (approx. £38.81 / €46 / AU $66).
Oculus Rift
As a rough-and-ready price comparison. The HTC Vive, which includes a headset with front-mounted “see-through” camera, two controllers and two room sensors for tracking) is prices at about US $800. The Oculus Rift (which ships with one sensor) + touch + and additional sensor comes to roughly US $877, with some recommendingtwo additional sensors offer optimal scanning bringing that total to US $956. Obviously, the latter package also includes a hefty amount of additional software, including Toybox.
On November 10th 2016, Oculus VR confirmed they were lowering the minimum specification for hardware needed to run an Oculus VR experience comfortably, as a result of something called Asynchronous Spacewarp, or AWS. The announcement came with a long and involved description of what AWS is, which the press announcement summarised down to a TL;DR summary:
Oculus is releasing a new technology aimed at reducing system hardware requirements while maintaining content quality across a wider array of hardware. Asynchronous Spacewarp (ASW) is a frame-rate smoothing technique that almost halves the CPU/GPU time required to produce nearly the same output from the same content. Like Asynchronous Timewarp (ATW), ASW is automatic and enabled without any additional effort from developers.
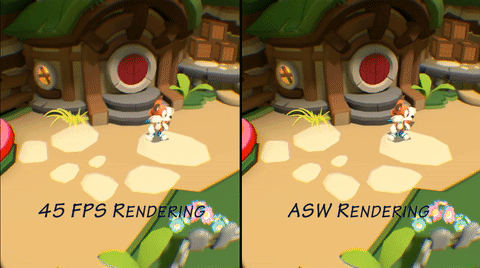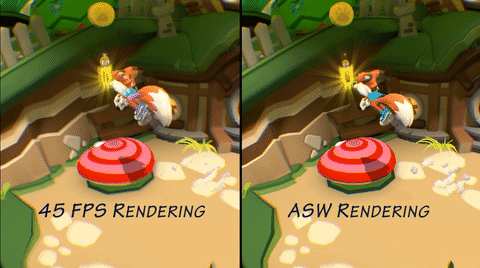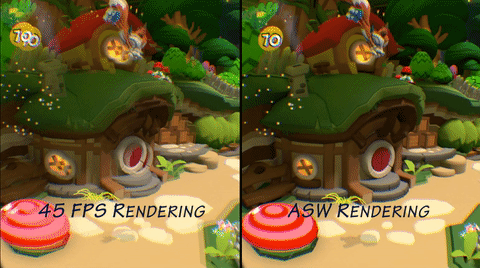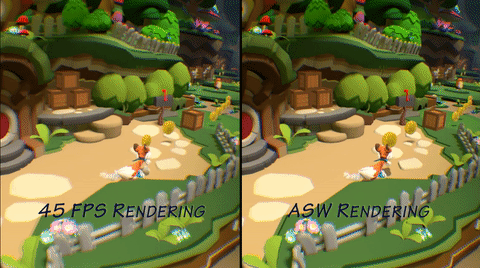
In other words, and to summarise the summary, AWS allows VR experiences remain fluid to the eye by “making up” the “in-between” animation frames, reducing the demand of continued, heavy processing on the part of the CPU / GPU.
On the left, a game with every frame directly rendered at 45fps by the GPU. On the right, the same game using software AWS to render some of the “in-between” animation frames, where the direction of the fox’s motion is “known”. Credit: TechRadar
This is turn means that “lower end” systems can now in theory run VR experiences which incorporate AWS. Although it has to be said that “lower end” must be approached with something of a caveat: it reduces the GPU requirement from a minimum of a NVIDIA GTX 970 / AMD Radeon R9 290 and Intel i5-4590 equivalent or greater to a NVIDIA GTX 960 / AMD Radeon RX 470 or greater and Intel i3-6100 / AMD FX4350 or greater – which some might consider a small move of the needle.
Finally, Oculus VR is working on an untethered version of the Rift headset, currently called Santa Cruz. It appeared in prototype form in October 2016, and includes a built-in processing system mounted with the headset, removing the need for it to be connected to a PC. Initial reports from those able to try the prototype were mixed, with several reporters noting their evaluations were carefully controlled, and that Oculus engineers were evasive when asked about the actual processing power and performance of the headset.
HTC Vive
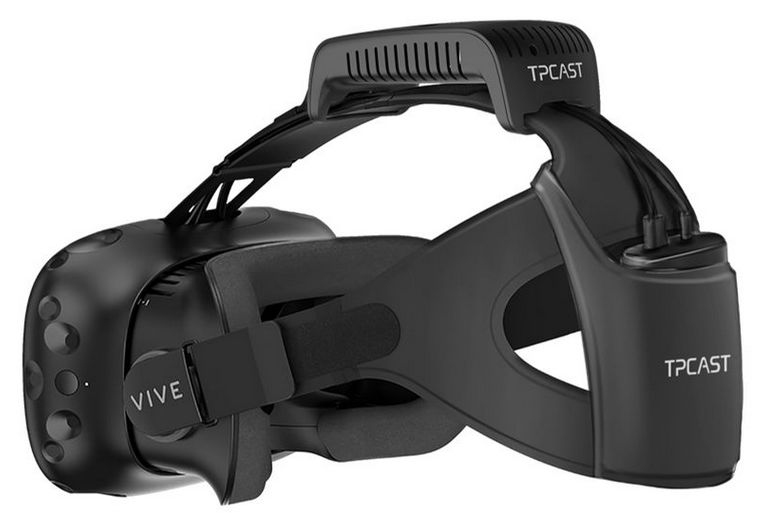
On November 11th, 2016, HTC announced pre-orders were open for a “tether-less” kit for the Vive headset, produced by TPCAST, a Vive X Accelerator invested company. The kit comprises a wireless relay unit and battery pack to power the headset, bot of which attach to the headset harness, removing the need to connect it to a PC via USB cables. In difference to claims that wireless is “unsuitable” for VR due to factors such as latency, TPCAST is said to have no “noticeable difference” when using it with a Vive headset when compared to using the headset tethered directly to a PC.
The TPCAST wireless kit mounted on a HTC Vive. Credit: HTC / TPCast
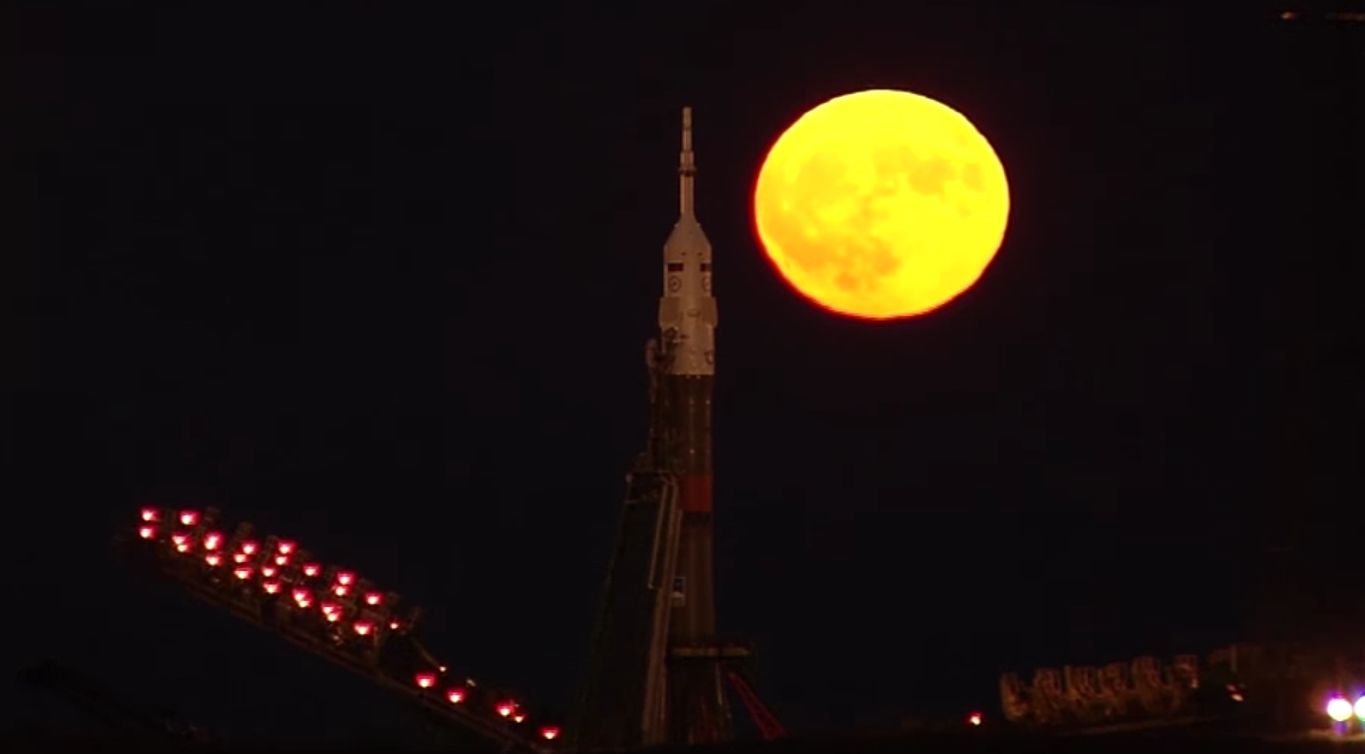
The “supermoon” of November 14th rises over the Soyuz MS-03 spacecraft the Baikonur Cosmodrome in Kazakhstan, where it was being prepared for launch to the International Space Station. Credit: NASA
The second of the three so-called “supermoons” which see out 2016 produced some dramatic photographs and video from around the world. Perhaps one of the most stunning came from cameras at the Baikonur Cosmodrome in Kazakhstan, monitoring Soyuz MS-03 as it stood on the pad at Launch Complex 1.
As I noted in my last Space Sunday Report, a “supermoon” occurs when the Moon is both full and at perigee – the point in its orbit when it is closest to the Earth as it travels around our planet in an elliptical orbit. Such events occur around every 14 months, and can see the Moon appear to be 14% bigger than its average size in our sky, particularly when seen low on the horizon.
The “supermoon” of November 14th was special because the Moon was about at its closest point to Earth in its orbit – “just” 356,509 kilometres (221,524 miles) from us and the Earth / Moon system is approaching the time of year when it is closest to the Sun (which will occur on January 4th, 2017), thus making the full Moon “extra” bright for those who were able to see it. The next time this will occur will be in 2034. However, December 14th will see another “supermoon”, albeit one at a slightly greater distance away from the Earth, so those who missed November’s – weather permitting – may still get to see one before the year is out. In the meantime, here’s NASA’s footage from Baikonaur – the film obviously speeded-up 🙂 .
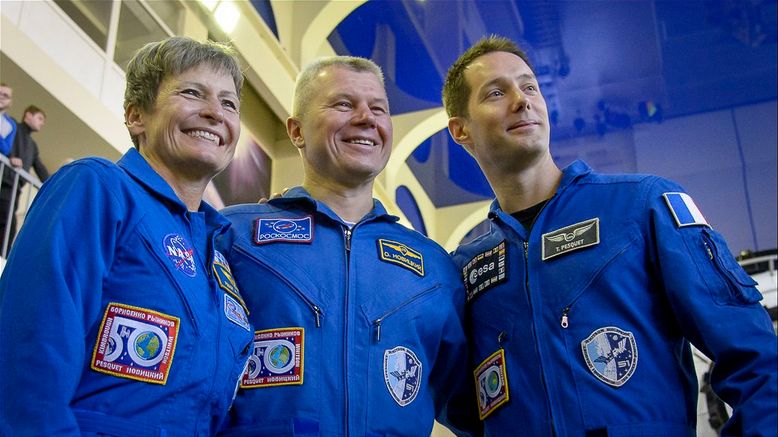
Soyuz MS-03 lifted-off from Baikonur on Friday, November 18th, carrying aloft Russian cosmonaut Oleg Novitskiy, American astronaut Peggy Whitson and rookie French astronaut Thomas Pesquet. It successfully docked with the International Space Station on Saturday, November 19th, marking the start of the Expedition 50/51 mission aboard the station, the crew sharing space with the Expedition 49/50 crew of mission commander Shane Kimbrough of NASA and Russian cosmonauts Sergey Ryzhikov and Andrei Borisenko, who have been aboard the station since October and who are due to return to Earth in February 2017.
For Whitson, this is a double first: she is the oldest woman to ever fly to the ISS – she will celebrate her 57th birthday in orbit – and, come February, she will be the first woman to command the space station for a second time in its 16-year operational history, having already become the very first woman to take command during Expedition 16 in 2007. She is also NASA’s most experienced female astronaut, with nearly 377 days logged in space, including six space walks totalling 39 hours 46 minutes. By the time she returns to Earth, she will have spent more time in space than any other US astronaut, surpassing the 534-day record set by Jeff Williams in September 2016.
Peggy Witson with Oleg Novitskiy and Thomas Pesquet posing for photographs prior to launch. Via: Peggy Whitson
During their time aboard the station, Whitson, Novitskiy and Pesquest will conduct hundreds of experiments and studies in biology, biotechnology, physical science and Earth science. A particular focus will be recording how lighting impacts the overall health and well-being of station crew members, and how the microgravity environment in orbit affects tissue regeneration in humans and the genetic properties of space-grown plants.
The crew carry with them some special meal time treats as well. Taking a leaf from British astronaut Tim Peake’s book, Pesquest requested fellow countrymen and renowned chefs Alain Ducasse and Thierry Marx develop a special menu for the crew. Highlights include beef tongue with truffled foie gras and duck breast confit.
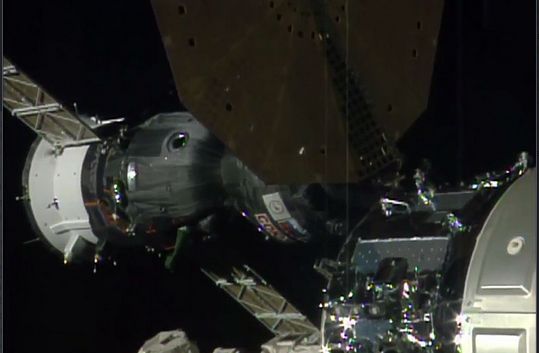
Soyuz MS-03, piloted by commander Oleg Novitskiy, closes for a docking with the Russian-built Rassvet module on Saturday, November 19th. In the foreground is the Cygnus resupply vehicle which recently arrived at the space station, one of its circular solar power arrays partially blocking the view of the incoming Soyuz. Credit: NASA
“We have food for the big feasts: for Christmas, New Year’s and birthdays. We’ll have two birthdays, mine and Peggy’s,” the Frenchman said at the astronauts’ last press conference before the launch.
Pesquest, a former commercial airline pilot with Air France, is also set to offer some entertainment for the crew: a keen musician, he’s taken his saxophone to the ISS. As part of his work on the station, he has special responsibility for the Proxima research programme of 50 experiments developed by the European Space Agency and the French national space agency, CNES. The programme’s name was suggested by 13-year old Samuel Planas from Toulouse, France, following a nationwide competition among school children. It is taken from Proxima Centauri, with the X in the name both representing the unknown, and the fact that Pesquest is the tenth French astronaut to fly in space.
Oleg Novitskiy, a 45-year-old lieutenant colonel in the Russian Air Force, is also on his second mission aboard the ISS, having previously served as the Soyuz TMA-06M commander during the flight to the ISS, and as the station’s flight engineer during Expedition 33/34. He has spent 143 days 16 hours and 15 minutes in space.
An artist’s impression of a “super Earth” type planet in orbit around a red dwarf star. Credit: NASA / Dana Berry.
In a couple of recent Space Sunday reports, I covered the discovery of an Earth-size planet orbiting our nearest stellar neighbour, the red dwarf Proxima Centuari (see here and here). Red dwarfs are a class of star which has proven rich ground for planet hunters – and this has once again proved the case.
The European Southern Observatory ESO), one of the leading hunters of exoplanets, has reported the discovery of a “super Earth”, a sold planetary body with roughly five times the mass of Earth. It is orbiting GJ 536, an M-class red dwarf star some 32.7 light years from the Sun. The planet is orbiting its parent once every 8.7 days, at a distance of 0.06661 AU.
The planet was discovered using a pair of instruments operated by ESO: the High Accuracy Radial velocity Planet Searcher (HARPS), mounted on ESO’s 3.6 metre telescope at the La Silla Observatory in Chile, and its sister instrument, HARPS-N, at the La Palma Observatory in Spain. The findings from these instruments were combined with photometric data from the All Sky Automated Survey (ASAS), which has observatories in Chile and Maui, to confirm the existence of the planet.
Red dwarf stars are entirely convective in nature, making them extremely volatile in nature, and subject to massive stellar flares. Credit: NASA/CXC/M.Weiss
However, its was no rapid-fire discovery. In all, data from over eight years of observations of the star went into confirming the presence of the planet. Such is the extended period of observations, that the science team were able to gather a huge amount of spectroscopic data on the star. This has revealed it has a rotational period of about 44 days, and magnetic cycle that lasts less than three years. By comparison, the Sun has a rotational period of 25 days and a magnetic cycle of 11 years.
This indicates that GJ536 is, in keeping with most red dwarf stars, exceptional volatile. Such stars are so small, all activity within them is entirely convective in nature, which gives rise to massive stellar flares. So while the new planet may well have “earth” in its description, it is unlikely to be “Earth like”, particularly given its relatively close proximity to its parent star.
Not much more is known about the planet at this point, but this is liable to change over time, and in the meantime, the survey team will continue to gather data on GJ 536 to see if it is home to other planets, such as gas giants further away from it.
November’s Supermoon
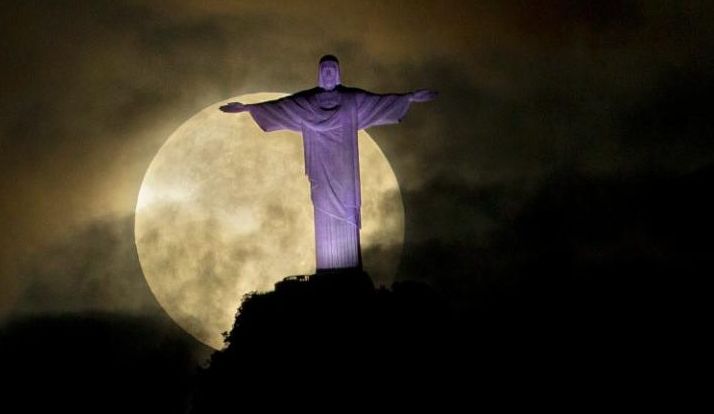
A dramatic supermoon is seen behind the Christ the Redeemer statue in Rio de Janeiro, in May 2012. Credit: AP Photo/Victor R. Caivano
The last three months of 2016 are marked by three so-called “supermoons”, and the biggest will be in the night skies on Monday 14th November 2016.
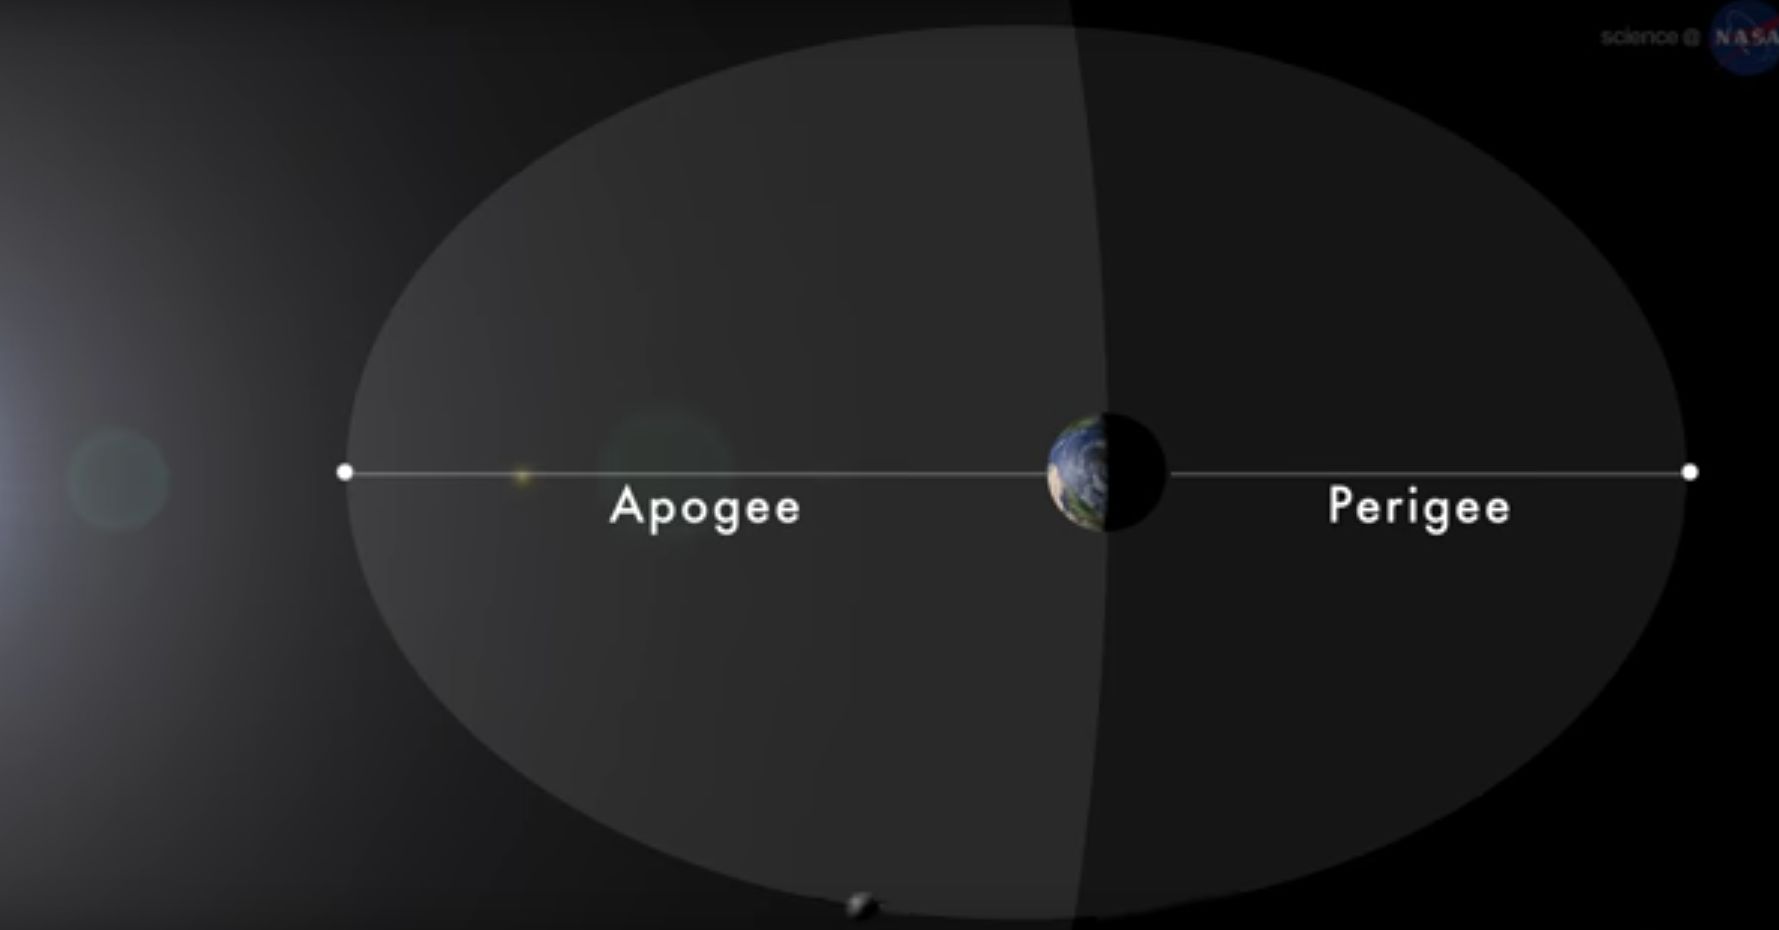
The Moon is in an elliptical orbit around the Earth, at apogee, the point furthest from the Earth, it is between 404,000–406,700 km (252,500-254,187 mi) from Earth. At perigee, the point closest to the Earth, the Moon is between 356,400–370,400 km (222,500-231,500 mi) away. A “supermoon” occurs when the Moon is both full and at perigee, when it can appear up to 14% large in diameter than “normal” full moons.
Apogee and perigee in the Moon’s orbit around Earth. Credit: NASA
“Supermoons” aren’t actually rare events; they take to occur once every 14 months on average. However, the supermoon on November 14th, scores double. Not only will be “just” 356,509 kilometres (221,524 miles) from Earth, pushing it to that 14% increase in apparent size, but also because the Earth/Moon system is approaching the time of year when it is closest to the Sun (which will occur on January 4th, 2017). Therefore, the Moon will be receiving more sunlight than average, further boosting its apparent brightness.
Together, these two events mean that the Moon will be at its “largest” and brightest in the sky since 1948. The next comparable event will not occur again until 2034 – although there will be a further “supermoon” on December 14th, when the Moon again reaches its full phase, but it will be slightly further away from the Earth in its orbit at that time, so not quite as “super”.
How the Moon can appear to differ in size at apogee (the point furthest from Earth in its orbit) and perigee (the point in its orbit closest to Earth). Credit: Catalin Paduraru
The 2016 conference will be over two days: Saturday 10th and Sunday 11th December, with social events being held in the run-up to, and around the dates of, the conference itself.
Since seats are limited, registration is open on a first-come-first-served basis until the maximum number of virtual conference centre tickets is reached. At that point, community members will still be able to register for the live streamed version of the conference that will be available.
Attendance is free, but those wishing to financially support the conference can sponsor or participate in the OSCC Crowdfunder Campaign when registering. Participants in the Crowdfunding Campaign will receive a variety of thank you gifts depending upon their level of participation, including early access, conference promotional items, and ability to have a virtual expo booth at the event.
In addition, the organisers are still seeking individuals and groups willing to host social events If you are interested, please complete the Community Events Sign-up page.
Volunteers are also still being sought as:
Greeters / audience helpers
Moderators
Builders
Scripters
Social Media / Communications
Streaming and Technical Support
Those interested in volunteering can do so via the Volunteer Sign-up form, Depending upon their interests, volunteers can select more than one role if they wish.
About the Conference
The OpenSimulator Community Conference is an annual conference that focuses on the developer and user community creating the OpenSimulator software. The conference is a joint production by Core Developers of OpenSimulator and AvaCon, Inc., a 501(c)(3) non-profit organization dedicated to promoting the growth, enhancement, and development of the metaverse, virtual worlds, augmented reality, and 3D immersive and virtual spaces. The conference features a day of presentations, panels, keynote sessions, and social events across diverse sectors of the OpenSimulator user base.